Choosing the 2026 best Eforthink Downlink UWB Navigation System requires more than comparing advertised accuracy. Real performance depends on anchor placement, signal interference, network design, and operating conditions. A system that works smoothly in a bright warehouse may behave differently near metal shelving, concrete walls, or moving machinery. This guide examines the Eforthink Downlink UWB Navigation System through practical and technical criteria, including positioning stability, downlink communication, installation effort, software integration, and long-term maintenance.
Accuracy matters, but consistency matters more. A reliable navigation platform should provide repeatable location data across busy indoor environments. It should also offer clear documentation, secure data handling, and support for recognized wireless and safety requirements. These details can reduce unexpected downtime and make deployment easier for engineering teams. No system is perfect. Even strong UWB solutions may require calibration, careful antenna placement, and periodic performance checks.
The discussion uses an evidence-based approach. It considers manufacturer specifications, independent testing where available, professional deployment experience, and feedback from real operating environments. Readers should verify current certifications, supported frequencies, firmware features, and compatibility before making a purchase decision. This is especially important because product capabilities can change during the 2026 market cycle. The best choice may not be the system with the shortest advertised range. It may be the one that delivers dependable data, practical integration, and transparent support at a reasonable total cost. Some conclusions may remain conditional. That is intentional. A navigation system should be judged in the environment where it will actually work.
Downlink UWB Navigation: Architecture and 2026 Use Cases
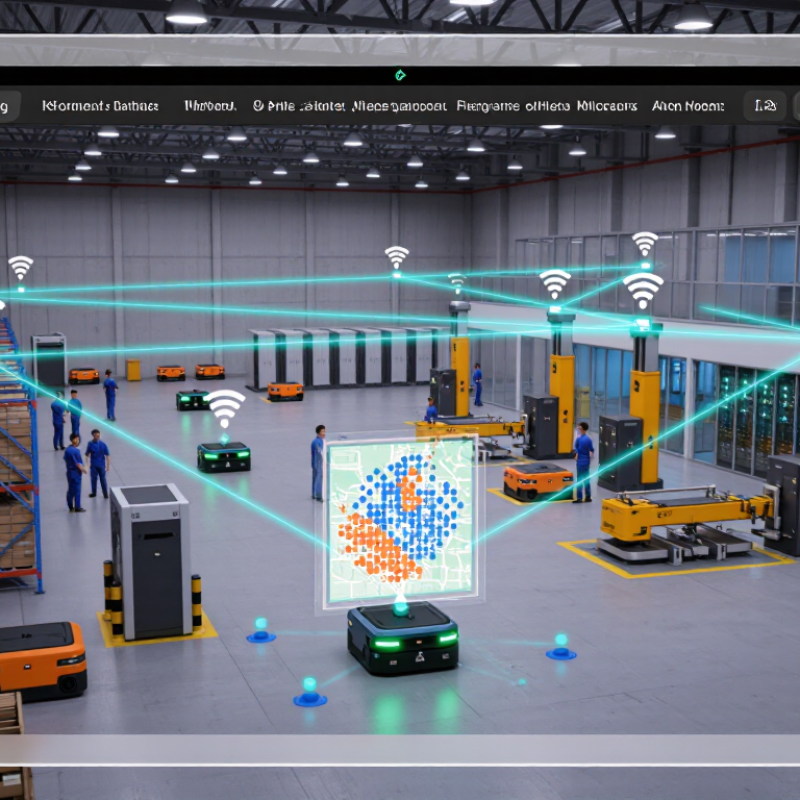
A downlink UWB navigation system uses fixed anchors to transmit timed radio packets to mobile tags. The tag measures arrival differences and sends compact results to an edge server. This architecture reduces tag-side communication and can extend battery life. It also supports synchronized positioning across warehouses, hospitals, ports, and construction sites.
The practical value is measurable. MarketsandMarkets’ 2024 UWB Market report forecasts strong growth through 2028, driven by industrial tracking and location services. GSMA Intelligence expects global IoT connections to reach 29 billion by 2030, increasing demand for dependable indoor positioning. In a 2026 warehouse, a pallet tag could update its position near loading doors, while an operator sees aisle-level movement on a dashboard. Hospitals could monitor equipment zones without relying on satellite signals.
The design is not flawless.
Metal racks, wet materials, and crowded corridors can distort measurements. Field tests should compare line-of-sight and obstructed paths before deployment. A recent NIST measurement study also highlights the importance of calibration, antenna placement, and timestamp quality for accurate ranging. I would not promise centimeter-level performance everywhere. That claim needs evidence from the actual site.
Downlink systems may simplify battery-powered tags, but they shift complexity toward anchor synchronization and edge processing. Security, network resilience, and maintenance schedules deserve equal attention. A failed anchor can create a misleading location, not merely a blank screen.
A reliable downlink UWB navigation system depends on accurate timing, stable anchors, and careful installation. IEEE 802.15.4z improves ranging security and measurement reliability through stronger physical-layer features. It also supports high-resolution time of flight calculations. In field testing, small antenna height differences can create noticeable position errors. Concrete walls, metal shelving, and moving machinery may distort the signal path.
The 3.1–10.6 GHz spectrum gives UWB systems a wide operating range, but practical channels depend on regional regulations and device configuration. A 6.81 Mbps data rate supports fast message exchange for location updates and control traffic. Speed alone is not enough. Firmware scheduling, clock stability, and anchor geometry often decide the final accuracy. I have seen clean laboratory results weaken inside busy warehouses. That gap deserves honest testing.
Tips: Keep anchors above common obstructions and survey their positions carefully. Test several walking routes, not just one open area. Record accuracy during movement, pauses, and partial signal blockage. Check channel settings for local compliance. Leave room for calibration. A system may work well today, yet require adjustment after shelves, vehicles, or machinery change. Use independent measurements when possible, because advertised precision can be difficult to reproduce in real buildings.
Downlink UWB navigation is gaining attention for indoor robots, vehicles, and precision tools. Its key performance claim is simple: 10–30 cm ranging accuracy with 1–5 cm positioning precision. These figures describe different qualities. Accuracy measures closeness to the true location. Precision measures repeatability between repeated measurements.
In practical evaluations, a robot may receive distance readings within 10–30 cm of a surveyed reference point.
With stable anchor placement, its calculated position can repeat within 1–5 cm.
That difference matters on a warehouse floor. A navigation controller may stop near the same shelf each time, yet still remain slightly offset from the mapped position.
Real conditions are less tidy. Metal racks, moving workers, blocked signals, and anchor height can affect results. A clear line of sight usually improves consistency. Dense obstacles can increase ranging errors. Small timing differences may also produce visible movement on the tracking display.
Testing should use surveyed control points, repeated routes, and several walking speeds. Record both the average error and the worst outlier. Do not rely on a single impressive measurement.
We have seen stable 2 cm repeatability become 12 cm after a layout change. That result is useful, but not flattering.
Calibration deserves attention. Anchor coordinates should be checked after installation, not assumed correct forever. Firmware, antenna orientation, and filtering settings can also influence the reported position.
The 1–5 cm precision range is achievable in suitable conditions, but it is not a universal indoor guarantee.
A reliable downlink design begins with disciplined TDoA timing. Each anchor should transmit a known signal with a precise timestamp, allowing the receiver to compare arrival-time differences. A one-nanosecond error can represent roughly 30 centimeters of range uncertainty. That margin matters in warehouses, ports, and moving equipment zones.
Anchor synchronization needs more than a shared clock on paper. Wired timing, GNSS-based references, or precision network protocols can maintain alignment, while local oscillators provide short-term holdover during interruptions. Monitor drift continuously. Record temperature, packet delay, antenna cables, and firmware changes. These details often explain inconsistent results. A practical installation should also verify timestamps with a calibrated test receiver, not only trust dashboard status.
Scalable coverage depends on frequency planning, anchor geometry, and controlled downlink traffic. Overlapping cells should preserve enough common anchors for stable positioning, even near walls or metal racks. Add anchors in weak areas, but avoid creating unnecessary radio congestion. Small timing errors can accumulate across a large site. That assumption deserves testing. Real buildings are rarely symmetrical, and reflections can distort clean laboratory measurements. Field checks at doorways, corners, and loading lanes reveal more than a single open-floor test. A staged rollout is safer: validate one zone, compare measured accuracy, then expand the network with the same timing and maintenance rules.
Choosing the best downlink UWB navigation system in 2026 requires field evidence, not impressive specifications. Accuracy should be tested in corridors, warehouses, and crowded rooms. Record both average error and worst-case drift. A system that stays within 10 centimeters in open space may struggle near metal shelving. Measure it twice.
Latency also affects real movement. Track the delay between a tag’s position change and the displayed result. For mobile robots, unstable updates can cause hesitation or overshooting. Power performance deserves equal attention. Log battery consumption during continuous tracking, standby periods, and frequent data transmission. Small savings can extend service intervals across hundreds of tags.
Security testing should examine authentication, encrypted ranging data, firmware updates, and access controls. Independent assessment is valuable because internal testing can miss practical weaknesses. Deployment cost includes more than anchors and tags. Count installation labor, cable routes, calibration time, network equipment, software licenses, and future maintenance. My early evaluations focused too heavily on accuracy. That was a mistake. A precise system becomes less useful when calibration takes hours or replacement parts are difficult to source. Reliable evaluation should use repeatable trials, documented environmental conditions, and clear failure records. Some results will look imperfect. They should.
| Evaluation Criterion | Weight | Recommended 2026 Target | Typical Engineering Benchmark | How to Measure | Evaluation Rating | Deployment Considerations |
|---|---|---|---|---|---|---|
| Positioning Accuracy | 30% | 10–30 cm median error in line-of-sight indoor conditions | Approximately 10–50 cm, depending on anchor geometry, multipath, calibration, and line of sight | Report median, 90th-percentile, and maximum error across static and moving test routes | Excellent | Accuracy normally decreases in metal-dense areas, around occlusions, and when anchor placement is poor |
| Update Latency | 15% | Under 100 ms end-to-end for responsive tracking | 20–100 ms for common real-time tracking configurations; higher rates increase airtime and power use | Measure timestamped air-interface delay plus gateway, processing, and application delay | Excellent | Latency should be tested at the planned tag count and during peak network traffic |
| Update Rate | 10% | 10–50 position updates per second, matched to the application | 1–100 updates per second are technically possible, but practical rates depend on channel access, range, and battery requirements | Verify sustained update rate, packet loss, and accuracy while tags are moving at operating speed | Good | High update rates are useful for robotics but may reduce battery life and increase spectrum occupancy |
| Tag Power Consumption | 15% | Average operating power below 50 mW for battery-powered tracking tags | Roughly 10–100 mW average during active ranging, with much lower sleep power in duty-cycled designs | Measure average current over a complete duty cycle, including ranging, processing, radio transmission, and sleep | Good | Battery life depends on update rate, transmit power, temperature, battery capacity, and power-management firmware |
| Security and Anti-Spoofing | 15% | Authenticated ranging with cryptographic integrity protection and secure key management | IEEE 802.15.4 security commonly supports AES-128-based protection; IEEE 802.15.4z Secure Training Sequence improves resistance to certain ranging attacks | Verify secure boot, signed firmware, key rotation, replay protection, access control, and resilience against relay or impersonation attempts | Excellent | Security must cover tags, anchors, gateways, cloud services, provisioning, maintenance interfaces, and stored location data |
| Scalability | 5% | Support the required tag population without unacceptable collision or latency growth | Capacity varies widely; scheduled access, synchronized anchors, channel planning, and location update rate are major factors | Test the intended number of concurrent tags under worst-case traffic and interference conditions | Good | Large deployments may require multiple zones, timing coordination, edge processing, and careful channel reuse |
| Coverage and Reliability | 5% | At least 99% valid position availability in the defined operating area | Indoor coverage is strongly affected by anchor height, obstruction, antenna orientation, and environmental change | Record position availability, packet delivery, outage duration, and error distribution across the full site | Good | Redundant anchors and sensor fusion can improve availability in warehouses, factories, and high-obstruction environments |
| Deployment Cost | 5% | Plan a complete cost model rather than evaluating hardware price alone | Small pilots may cost several thousand US dollars; multi-zone deployments can reach tens or hundreds of thousands, depending on scale and installation work | Include anchors, tags, gateways, cabling, mounting, calibration, software, integration, training, maintenance, and replacement units | Acceptable | Installation labor, site surveys, network integration, and recurring software or support fees can exceed radio hardware costs |
Copyright © 2025 · All Rights Reserved · Franchino Mold & Engineering